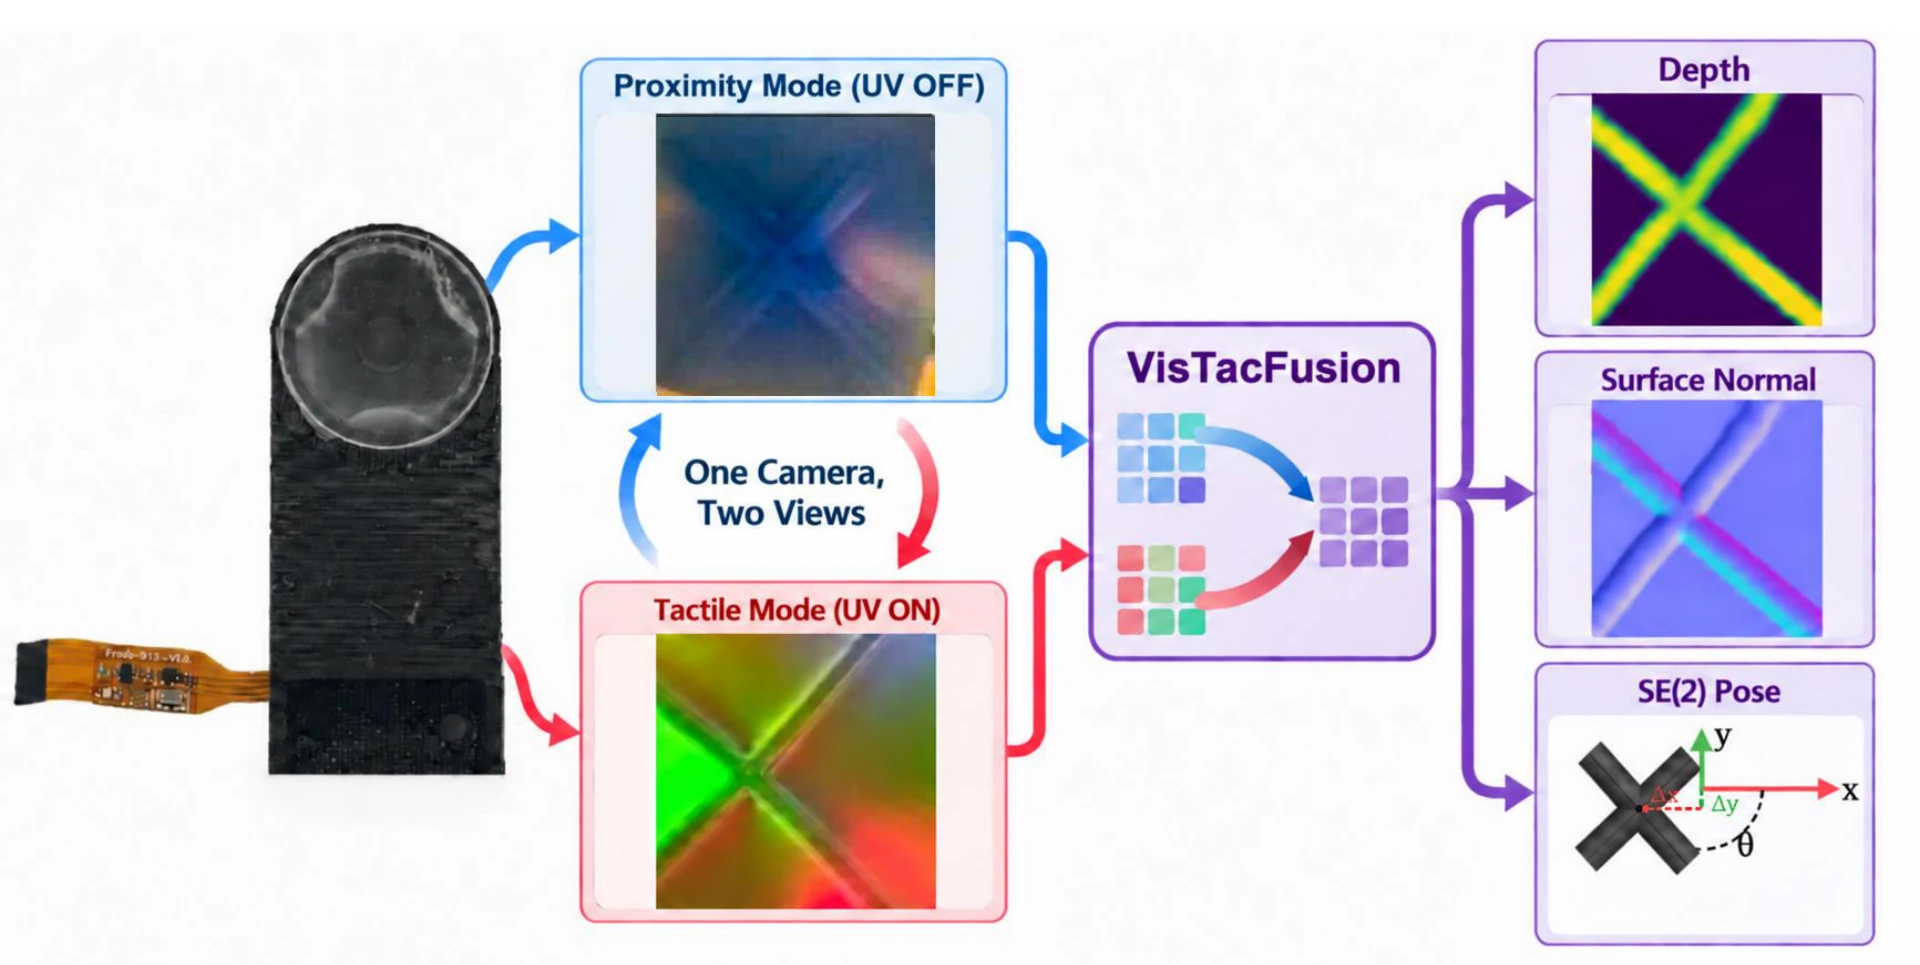
GelSlim 5.0: Unifying Vision and Touch with a Single Fingertip Camera
A fingertip tactile sensor whose single camera either looks through its gel skin or reads contact, depending on the lighting, plus a model that fuses both views to estimate object pose and contact shape.
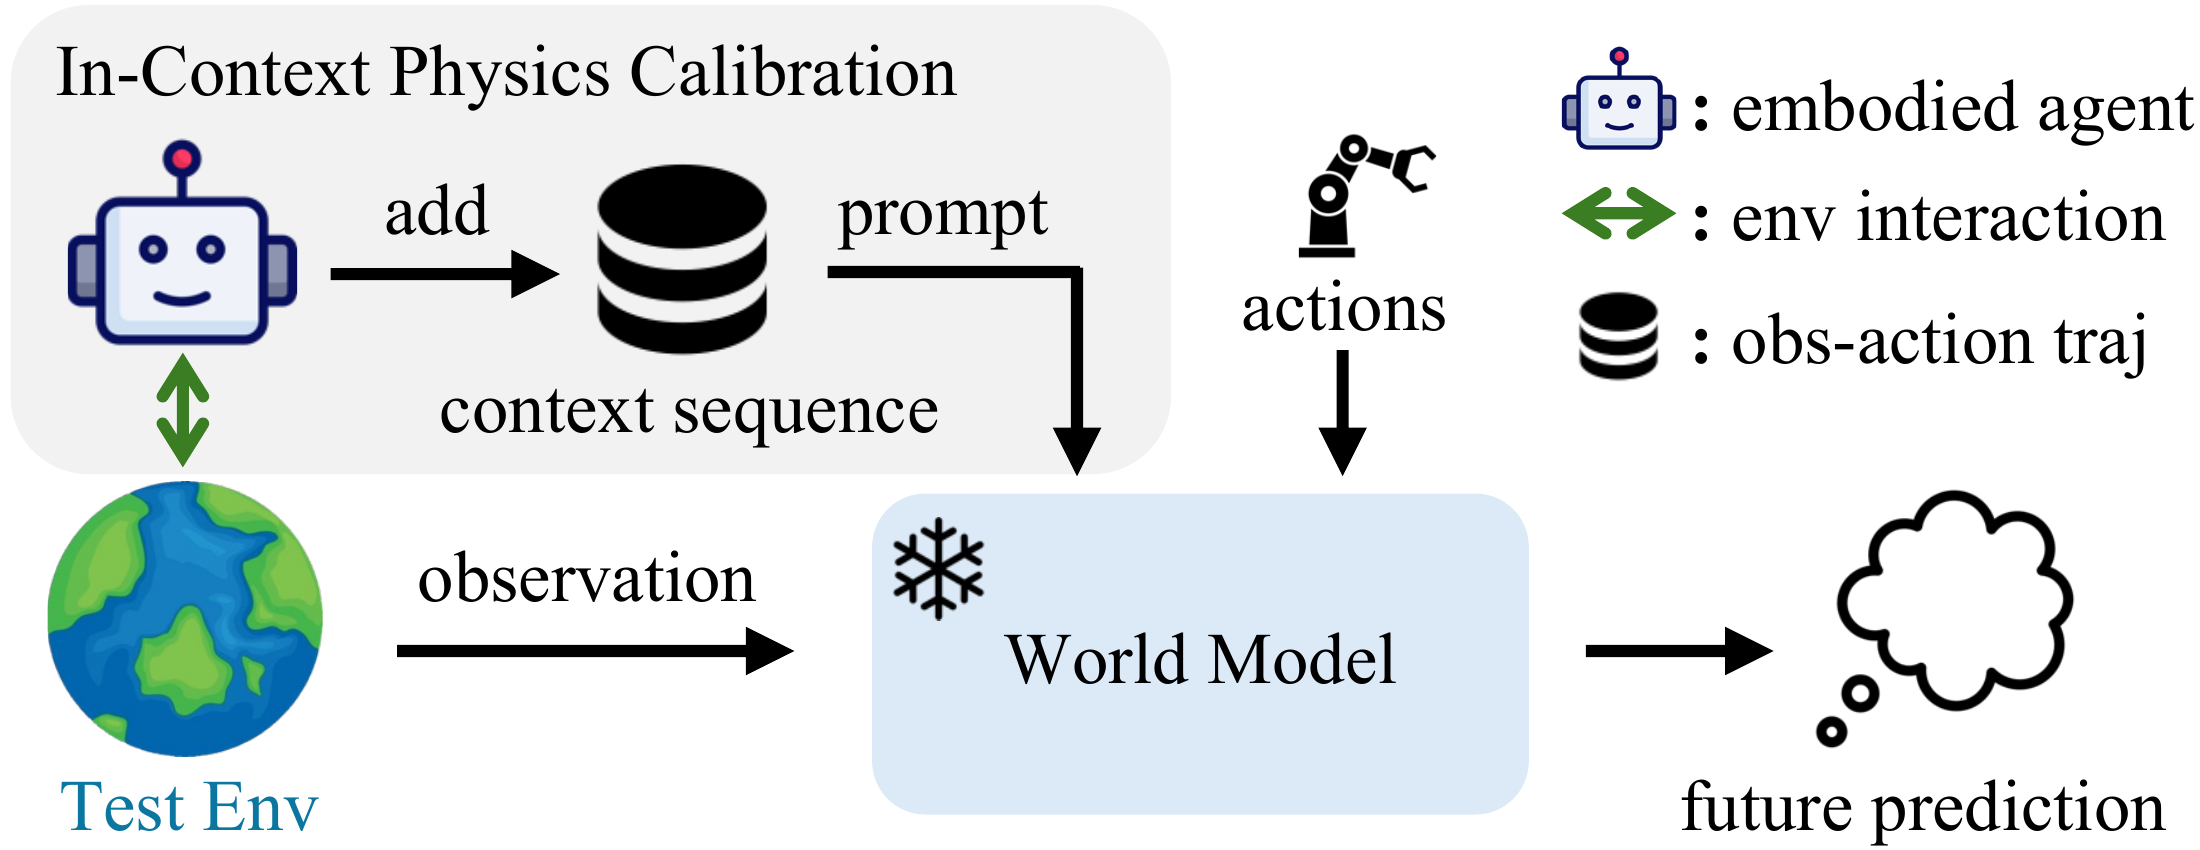
PhysiCalWorld: In-Context Physics Calibration for World Models
Lets a world model adapt to the physics of an unfamiliar scene, such as friction or mass, by watching a brief exploratory interaction and condensing it into a token that steers its predictions, with no fine-tuning.
Tactile-Guided Robot Learning: From Representation...
Tactile-Guided Robot Learning: From Representation Learning to Foundation Models
A review of how touch is used in robot learning, from learned tactile representations and touch-aware policies to tactile foundation and world models, with open problems in transferring across sensors and robots.
HULK: Learning Whole-Body Forceful Loco-Manipulation for Humanoids
A whole-body controller that lets a humanoid walk, carry, and push while bearing heavy loads, trained with reinforcement learning guided by a model of how the payload shifts the robot's balance.
ReDex: Repairing Sim-to-Real Dexterous Policies by Finger-Level Compliant Interaction
Fixes simulation-trained dexterous hand policies that stumble on real hardware: a person physically guides only the struggling fingers, and those corrected runs, with fingertip force readings, train a stronger force-aware policy.
Tactile Sim2Real without Tactile Simulation via...
Tactile Sim2Real without Tactile Simulation via Bottlenecked Latent Reconstruction
Moves touch-based policies from simulation to real tactile sensors without simulating those sensors, by training on contact signals the simulator already provides and then mapping real sensor readings into that learned space.